Choosing the right Wheelchair Motor in 2026 is not simply a matter of selecting the highest wattage. A powerful motor can still feel unsuitable on a narrow hallway, steep ramp, or uneven pavement.
Dr. Rory Cooper, founder of the Human Engineering Research Laboratories, has said, “A wheelchair is an extension of the body.” That idea should guide every motor decision. The motor must match the user’s weight, chair design, daily distance, driving ability, and typical surfaces. A lightweight indoor chair may need smooth acceleration and quiet operation. An outdoor power wheelchair may require higher torque, sealed components, and dependable hill performance.
Start with real conditions.
Measure the combined user and chair weight. Consider bags, oxygen equipment, and occasional extra loads. Then compare torque, voltage, controller compatibility, battery capacity, and mounting space. A motor rated for flat floors may struggle beside a wet curb or loose gravel. Heat buildup can also reduce performance during long climbs.
Manufacturer specifications offer useful evidence, but they do not tell the entire story. Independent testing, service records, warranty terms, and technician support deserve equal attention. A motor that looks affordable may become expensive after installation changes or repeated repairs.
There is no universally perfect Wheelchair Motor. This is where many buying guides oversimplify the decision. A recommendation may change after a short trial drive. Notice vibration, braking response, turning control, and battery drain. Speak with a qualified mobility specialist before purchase, especially when replacing an existing drive system. Small differences can affect safety, comfort, and everyday independence.
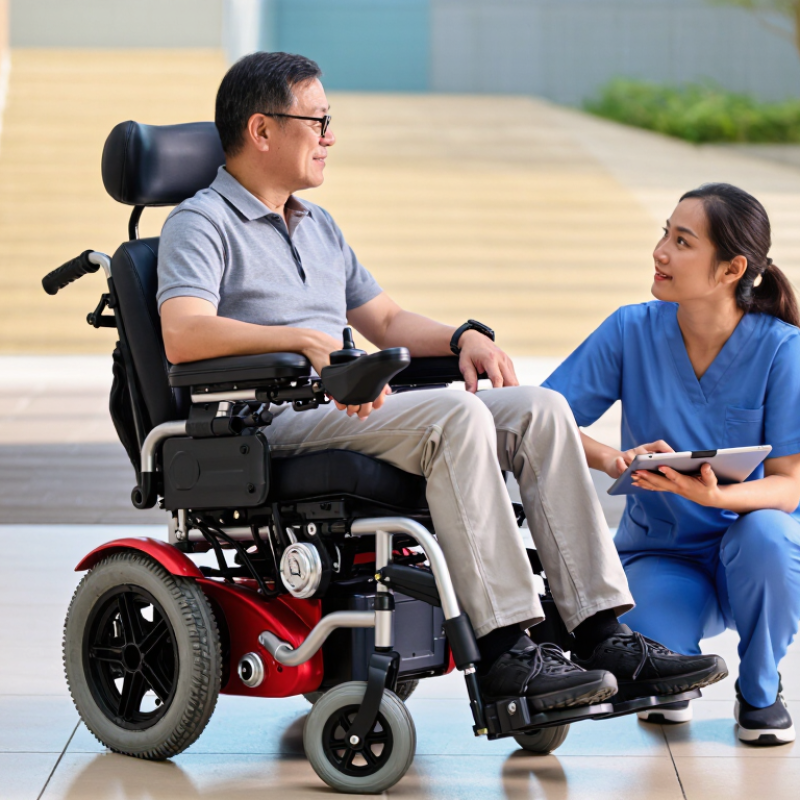
Choosing the right wheelchair motor in 2026 starts with duty cycle, not advertised peak power.
Record the user’s mass, chair mass, cargo, terrain, slope, and daily operating hours. Add them together. A 100-kilogram user on smooth indoor floors needs a different system from a 70-kilogram user climbing wet outdoor ramps.
Terrain changes the calculation quickly.
Grass, gravel, and broken pavement increase rolling resistance. Frequent slopes also demand more torque and create extra heat. For each route, measure the steepest grade and note how often it appears. A motor rated only for flat travel may overheat during repeated climbs.
Standardized testing and real routes
ISO 7176-4 provides a standardized method for wheelchair energy consumption and theoretical range testing, but real routes remain less predictable.
My own practical concern is simple: laboratory range can feel optimistic.
Daily hours matter just as much. Two hours of gentle movement may be easier than thirty minutes of repeated acceleration and hill climbing. Compare the motor’s continuous rating, thermal limits, and recommended duty cycle with actual use.
The 2022 WHO and UNICEF Global Report on Assistive Technology estimated that more than 2.5 billion people need assistive products worldwide. That scale highlights a basic engineering truth: one motor profile cannot fit every user.
Leave headroom, but not blindly. Oversizing adds weight, cost, and battery demand. Record the assumptions, then challenge them.
Choosing between 24–48 V motor systems starts with the chair’s load, terrain, and controller limits. A 24 V brushed motor remains practical for light indoor chairs. Its simple design is easy to service, but brushes wear under frequent starts. A 36 V system can improve climbing performance without greatly increasing battery size. For heavier users or outdoor routes, 48 V reduces current demand at similar power. That can mean cooler cables and less voltage drop.
Brushless motors run more efficiently and need less routine maintenance. They also require compatible sensors and control electronics, increasing repair complexity. Hub motors place torque directly at the wheel. They save drivetrain space, yet wheel removal and unsprung weight can complicate servicing. Geared motors deliver strong low-speed torque, especially on ramps. Gear noise and backlash may appear over time. Quietness matters indoors.
ISO 7176-14:2022 defines power and control-system test methods for electrically powered wheelchairs, so suppliers should provide comparable test results. The WHO and UNICEF Global Report on Assistive Technology estimates that more than 2.5 billion people need assistive products worldwide. That demand makes reliability more important than impressive peak speed. In practice, measure ramp angle, user weight, daily distance, and floor transitions. A motor rated for 48 V may still perform poorly with an undersized battery or poorly tuned controller. I would not choose solely from wattage. Real-world range can disappoint when cold weather, tyre pressure, and repeated curb crossings are ignored.
Choosing a wheelchair motor in 2026 starts with usable energy, not marketing wattage. Calculate motor power with P = V × I. A 24-volt system drawing 12 amps produces 288 watts. This describes electrical demand, not guaranteed wheel performance. Hills, user weight, tire pressure, and controller efficiency can change the result quickly.
Battery capacity uses Wh = V × Ah. A 24V, 20Ah battery stores about 480Wh. Keeping a 20% reserve leaves 384Wh for planned travel. At 288 watts, the simple estimate is 1.33 hours. Real range will be lower because motors rarely maintain constant current. ISO 7176-4 provides a standardized wheelchair range test, but daily pavement is less predictable. The WHO and UNICEF Global Report on Assistive Technology reports that more than 2.5 billion people need assistive products, highlighting why practical, reliable specifications matter. Still, one calculation cannot replace a supervised trial.
Tips: Record your route for three days. Note slopes, stops, and surface changes. Compare continuous motor power, peak current, battery Wh, and tested range. Ask whether the quoted range includes the 20% reserve. Check battery age, too. A worn battery may pass a capacity test yet sag under load. My estimate may be imperfect; temperature and neglected tire pressure can quietly consume range.
Motor input power is calculated as P = V × I. Battery energy is calculated as Wh = V × Ah. The estimated usable energy applies a 20% reserve: usable Wh = nominal Wh × 0.8. Range depends on terrain, weight, speed, tire pressure, and driving conditions.
Choosing a wheelchair motor in 2026 requires more than reading its advertised speed. ISO 7176-6 measures maximum speed under controlled conditions, while ISO 7176-10 evaluates obstacle-climbing ability. A motor reaching 10 km/h may still struggle with a steep curb, loose gravel, or a heavy user. Test results should include user mass, battery condition, tire pressure, surface, and slope angle. Otherwise, comparisons can mislead.
ISO 7176-14 examines power and control systems, including operating stability and electrical performance. It helps assess whether acceleration feels predictable and whether the motor responds safely under load. WHO and UNICEF reported in their 2022 Global Report on Assistive Technology that more than 2.5 billion people need assistive products globally. Nearly one billion people cannot access them. That scale makes reliable testing especially important. A specification is not a guarantee. Real streets remain less forgiving than laboratories.
Tips: Ask for test conditions, not only headline figures. Check the measured speed with your normal user weight. Request the tested obstacle height and surface type. Try a short incline with the chair fully loaded. Listen for motor hesitation. It matters. Also, compare battery voltage, controller limits, and braking behavior under ISO 7176-14 guidance. I would not choose the highest climbing figure automatically. It may increase heat, energy use, or control sensitivity. That assumption deserves a practical test.
Choosing the right wheelchair motor in 2026 involves more than speed, torque, and battery range. The complete wheelchair must remain compatible with vehicle transport requirements. ISO 7176-19 evaluates wheelchairs intended for use as seats in motor vehicles. It does not certify a motor alone.
Ask for clear testing documents for the exact wheelchair configuration. The report should match the frame, motor, battery placement, seating system, and accessories. A heavier motor can change the wheelchair’s mass and center of gravity. That may affect securement points and occupant restraint positioning. Check whether the chair provides accessible, clearly marked tie-down locations. Inspect them physically, not only in photographs.
Transport spaces are often narrow. Measure the folded or driving dimensions carefully. Confirm that the motor housing will not interfere with four-point restraints, docking equipment, or vehicle ramps. Batteries also deserve attention. Their mounting must resist movement during transport, and the electrical system should be protected from impact. Ask the supplier which components may be removed before travel.
Do not confuse “tested” with “safe in every setup.” That assumption is easy to make. A seat cushion, headrest, or aftermarket control can change the tested arrangement. I would recheck every modification before delivery, even when the motor specifications look correct. Keep the test report, user instructions, and inspection records together. A qualified rehabilitation or transport-safety professional can verify the final combination in the actual vehicle.
| Evaluation Dimension | What to Confirm Before Selection | Relevant Technical or Safety Data | Recommended Decision Rule | Evidence to Request |
|---|---|---|---|---|
| ISO 7176-19 scope | Determine whether the complete wheelchair, seating system, motor installation, and securement configuration have been evaluated for use as a seat in a motor vehicle. | ISO 7176-19 addresses wheelchairs intended for use as seats in motor vehicles. It does not certify a motor or drive unit by itself. | Accept only a complete, documented configuration; do not treat a motor datasheet as ISO 7176-19 compliance. | Complete wheelchair model, motor configuration, seating configuration, test report, and configuration limitations. |
| Transport mode | Confirm whether the wheelchair will be transported occupied or unoccupied. | Occupied transport requires an appropriate wheelchair securement system and an occupant restraint system. Unoccupied transport still requires suitable tie-down or cargo restraint. | Choose a motor installation that does not obstruct the prescribed securement points or occupant restraint path. | Transport instructions, securement-point diagram, restraint instructions, and user manual. |
| Four-point securement compatibility | Check whether the motor, battery tray, cables, brackets, and accessories interfere with front and rear securement points. | Wheelchair tie-down systems commonly use four securement points. The exact geometry and accessibility depend on the wheelchair design and the applicable securement system. | All designated points must remain visible, reachable, structurally suitable, and usable without removing the motor. | Securement-point locations, dimensional drawings, tie-down instructions, and installation photographs. |
| Wheelchair width and turning envelope | Compare the motor installation width, wheel position, turning clearance, and indoor maneuverability with the user’s environment. | Added drive components can increase overall width, turning radius, side clearance requirements, or risk of contact with door frames and furniture. | Reject any configuration that prevents safe access through required doors, ramps, lifts, or evacuation routes. | Overall dimensions with the motor installed, turning-radius data, and dimensional installation drawing. |
| Total mass and center of gravity | Assess the combined mass of the wheelchair, user, motor, batteries, controller, and accessories. | Added mass and a changed center of gravity can affect braking, ramp stability, loading limits, and transport securement loads. | Verify the complete system against the wheelchair’s rated user mass, component loading limits, ramp limits, and vehicle-lift capacity. | Weighed complete configuration, rated mass limits, center-of-gravity information, and lift/ramp capacity requirements. |
| Motor drive architecture | Match the drive layout to the wheelchair’s frame, suspension, caster arrangement, and intended terrain. | Rear-, mid-, and front-drive layouts have different traction, obstacle-climbing, turning, and caster-loading characteristics. An add-on drive unit may transfer additional loads to the frame or axle. | Select only a system approved for the exact wheelchair type and installation position. | Compatibility list, mounting instructions, axle/frame load limits, and terrain restrictions. |
| Rated slope and braking | Check the manufacturer-declared maximum slope, braking behavior, parking brake function, and rollback control. | Rated slope is application-specific and depends on total mass, surface, tire condition, battery state, and drive configuration. It is not established by ISO 7176-19. | Use a conservative operating limit and require independent parking stability on ramps and during transfers. | Operating limits, brake test data, rollback-control description, and warnings for wet or loose surfaces. |
| Battery chemistry and installation | Identify battery chemistry, nominal voltage, capacity, mounting location, protection, and removal requirements. | Battery voltage and capacity must match the motor controller and charger. Battery placement affects mass distribution and securement clearance. | Use only the specified battery and charger combination, with protected cabling and secure mounting. | Battery specification, charger specification, fuse or protection details, wiring diagram, and removal instructions. |
| Electrical safety | Review protection against overcurrent, short circuit, moisture, connector damage, and unintended drive activation. | Controls should include a reliable power isolation method and protection against accidental activation during transfers, loading, or transport. | Require documented electrical protection and a clearly accessible power-isolation procedure. | Electrical schematic, protection ratings, ingress-resistance information, fault behavior, and service instructions. |
| Transport power state | Confirm how the motor must be switched off and how the wheelchair must be prepared before vehicle movement. | Drive power should be isolated according to the manufacturer’s transport instructions. Freewheel or disengagement mechanisms must not compromise stability or securement. | The transport procedure must be simple, repeatable, and possible without removing essential safety components. | Step-by-step transport checklist, control-panel instructions, and freewheel/disengagement warnings. |
| Occupant restraint clearance | Ensure the motor, battery, arm supports, joystick, trays, and accessories do not interfere with the vehicle’s occupant restraint system. | Wheelchair securement and occupant restraint are separate functions. A wheelchair tie-down must not be used as a substitute for an occupant restraint. | The prescribed occupant restraint must contact the user correctly and remain free from obstruction by the motor installation. | Restraint routing diagram, prohibited contact points, seating restrictions, and transport-user instructions. |
| Emergency release and evacuation | Consider how the motor, battery, or parking brake affects emergency movement, manual pushing, and transfer. | Users and caregivers may need to disengage the drive system or isolate the battery during a fault or emergency. | Require a clearly labeled manual release or recovery procedure that does not depend on a powered control. | Emergency procedure, manual-push instructions, fault codes, and caregiver training requirements. |
| Standards and test evidence | Separate transport-safety evidence from general wheelchair performance and electrical-safety evidence. | ISO 7176-19 concerns wheelchair use as a motor-vehicle seat. Other ISO 7176 parts address subjects such as performance, stability, braking, dimensions, and power/control systems. | Request the exact standard edition, test scope, tested configuration, and any exclusions rather than accepting a general “standards compliant” claim. | Test reports, declarations, risk assessment, installation records, and applicable ISO 7176 references. |
| Serviceability and inspection | Plan inspection of mounting hardware, securement points, tires, brakes, cables, connectors, and batteries. | Loose mounting hardware, worn tires, damaged cables, or altered securement points can change safety performance and compatibility. | Establish inspection intervals and recheck the complete configuration after any motor, battery, seating, or frame modification. | Maintenance schedule, torque requirements, inspection checklist, replacement-part specifications, and modification controls. |
| Selection principle: Choose the motor only after confirming the complete wheelchair-and-motor configuration, transport securement points, occupant restraint clearance, total mass, center of gravity, battery installation, and documented evidence applicable to ISO 7176-19. ISO 7176-19 compliance should never be inferred from motor power, battery capacity, or a standalone drive-unit specification. | ||||
Record user mass, chair mass, cargo, terrain, slopes, and daily operating hours. Add these factors together.
Grass, gravel, and broken pavement increase rolling resistance. Repeated slopes demand more torque and create additional heat.
Not necessarily. A flat-travel motor may overheat during repeated climbs, especially with a fully loaded chair.
Compare continuous power, thermal limits, and recommended duty cycle with real use. Thirty minutes of hills may exceed two gentle hours.
No. Controlled speed testing may not reflect loose gravel, steep curbs, low tire pressure, or a heavier user.
Ask for user mass, battery condition, tire pressure, surface type, slope angle, and tested obstacle height.
Try a short incline with the chair fully loaded. Watch for hesitation, unexpected braking, or rising motor heat.
No. Extra capacity can increase weight, cost, battery use, and control sensitivity. I would leave headroom, but question every assumption.
Choosing the right Wheelchair Motor in 2026 begins with defining the user’s real operating conditions. Evaluate total user mass, terrain type, maximum slope, surface resistance, and expected daily operating hours to determine the required duty cycle. Compare 24–48 V systems, considering the practical differences between brushed, brushless, hub, and geared motors in efficiency, maintenance, torque, noise, and control response. A motor should be selected as part of a complete power system rather than by voltage alone.
Estimate performance with P = V × I and battery energy with Wh = V × Ah. Plan for at least a 20% energy reserve to account for temperature, battery aging, slopes, and changing terrain. Before finalizing the system, verify speed and climbing capability using the relevant ISO 7176-6, ISO 7176-10, and ISO 7176-14 testing principles. Finally, confirm that the motor, controller, battery, mounting structure, and braking system are compatible and meet transport safety expectations under ISO 7176-19.